Catalog
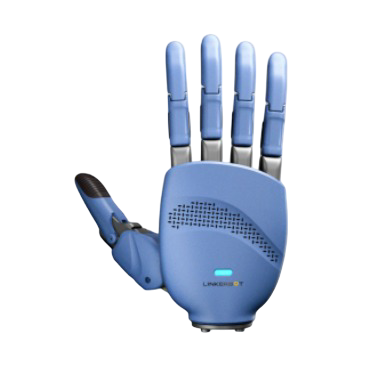
Linkerbot Dexterous Robotic Hand Linker Hand O6
Linker Hand O6 – 6-DOF High-Performance Dexterous Hand The Linker Hand O6 is a high-performance dexterous hand with 6 active joints and 5 passive joints, featuring strong grasping force, high-precision force control, compact size and lightweight build, perfectly suited for logistics handling, industrial assembly and irregular object grasping.Its compact and flexible structure lowers body payload while improving agility, enabling accurate and flexible operation even in confined spaces. The main body is made of aluminum alloy for light weight and high durability, ensuring long-term stable running for embodied intelligence training. Weighing only 370g, it supports a maximum payload of 50kg, thumb fingertip force up to 20N, four-finger force 25N, and five-finger grasping force up to 70N, with repeat positioning accuracy of ±0.2mm. Tactile sensors are optional for better sensing performance. It is widely used in logistics handling, industrial assembly, humanoid robots, embodied intelligence and various grasping scenarios, providing a reliable and high-performance dexterous operation solution for intelligent robotic applications.
规格参数
| max. Payload | 50 kg |
|---|---|
| DOF | 6 |
| Weight | 0.307 kg |